
Dynamic shift
A Dynamic shift changes how the world moves. It edits a physical parameter of the simulator, applies an external force to a body, or perturbs the simulator state between steps.
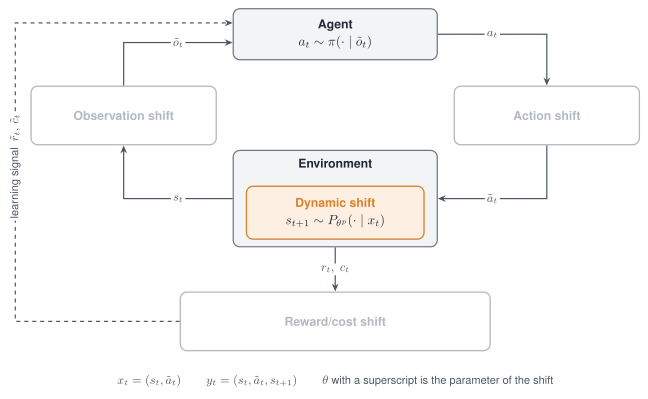
The Dynamic shift acts inside the environment: the next state is drawn from a shifted transition.
Properties
| Aspect | Dynamic shift |
|---|---|
| Perturbs | Physical parameters, external forces, the simulator state |
| Targets in code | dynamics and transition |
| Modes | Stochastic, Parametric, Non-stationary, Composition |
| Applied | Parameter edits at every reset; forces during a push; state noise after every step |
| Acts on a frozen policy | Yes |
| Simulators | MuJoCo for every mode name; Box2D for parameter edits |
Supported modes
| Mode | Mode name in code | What it does |
|---|---|---|
| Stochastic | gauss, uniform, loguniform |
Draws a factor once per episode and multiplies the nominal value by it |
| Stochastic | push |
Applies a force to one body for a few steps, at regular intervals, with a drawn direction and phase |
| Stochastic | gauss on the target transition |
Adds Gaussian noise to positions and velocities after every step |
| Parametric | scale |
Sets the parameter to its nominal value times a factor |
| Parametric | set |
Sets the parameter to an absolute value |
| Parametric | translate |
Adds an offset in metres to a position |
| Non-stationary | schedule on scale, translate, push and transition |
Varies the factor, offset, force or noise within the episode |
| Composition | Several shifts in one list | Edits several parameters at once |
The target transition accepts only the mode name gauss; any other mode name raises
ValueError when the environment is built. The Adversarial mode is not defined for this shift.
Parameters
Parameter edits on the target dynamics:
| Mode name | Parameter | Type | Default | Meaning |
|---|---|---|---|---|
all but push |
param |
str | required | Name of the physical parameter |
index |
int, str or "all" |
None |
Entity by position or by name, or every entity | |
scale |
factor |
float | 1.0 |
Factor on the nominal value |
set |
value |
float or list | required | Absolute value |
gauss |
mu, sigma |
float | 1.0, 0.1 |
Mean and standard deviation of the factor |
uniform |
low, high |
float | 0.8, 1.2 |
Bounds of the factor |
loguniform |
low, high |
float | 0.8, 1.2 |
Bounds of a factor drawn uniformly in log space; both positive |
gauss, uniform, loguniform |
operation |
str | "scale" |
With "set" the drawn number is the value itself |
nominal |
float | required with "set" |
The value a schedule multiplier of 0 maps to | |
translate |
offset |
list of float | required | Offset in metres |
External force and state noise:
| Mode name | Parameter | Type | Default | Meaning |
|---|---|---|---|---|
push |
body |
str | "torso" |
Body that receives the force |
interval |
int | 200 |
Control steps between the onsets of two pushes | |
duration |
int | 10 |
Control steps a push lasts | |
force |
float | 50.0 |
Magnitude in newtons | |
direction |
str or list | "random_xy" |
"random_xy", "random_x", or a fixed vector of three numbers |
|
gauss on transition |
q_sigma |
float | sigma, else 0.0 |
Standard deviation of the noise on positions |
v_sigma |
float | sigma, else 0.0 |
Standard deviation of the noise on velocities |
Names of physical parameters on MuJoCo tasks:
param |
Edits |
|---|---|
gravity, wind |
One component of the gravity or wind vector; by default the vertical component of gravity |
body_mass, body_inertia |
Mass of a body; first component of its inertia |
body_pos, body_pos_xyz |
Vertical component, or the full vector, of the offset of a body from its parent; the full vector scales limb length |
dof_damping, dof_frictionloss |
Damping and dry friction of a joint |
geom_friction |
Sliding friction of a geom |
geom_size, geom_size_xyz |
First size component, or the full size vector, of a geom |
actuator_gear |
Gear of an actuator, its control authority |
freejoint_pos |
Position of a free-floating body |
Box2D tasks use the names gravity, enable_wind, wind_power, turbulence_power,
main_engine_power, side_engine_power, engine_power and friction.
Declare the shift
Every example on this page passes the check below.
from robustrllib import make_robust, ShiftSpec


def check(spec, env_id="Hopper-v5"):
    env = make_robust(env_id, shifts=[spec], seed=0)
    env.reset(seed=0)
    env.step(env.action_space.sample())
    env.close()
Parametric:
PARAMETRIC = {
    "scale":     ShiftSpec("dynamics", "scale", {"param": "body_mass", "index": "torso", "factor": 1.5}),
    "set":       ShiftSpec("dynamics", "set", {"param": "dof_frictionloss", "index": "all", "value": 0.5}),
    "translate": ShiftSpec("dynamics", "translate", {"param": "body_pos_xyz", "index": "foot",
                                                     "offset": [0.06, 0.0, 0.0]}),
}
Stochastic:
STOCHASTIC = {
    "gauss":      ShiftSpec("dynamics", "gauss", {"param": "gravity", "mu": 1.0, "sigma": 0.05}),
    "uniform":    ShiftSpec("dynamics", "uniform", {"param": "actuator_gear", "index": "all",
                                                    "low": 0.8, "high": 1.2}),
    "loguniform": ShiftSpec("dynamics", "loguniform", {"param": "dof_damping", "index": "all",
                                                       "low": 0.5, "high": 2.0}),
    "absolute":   ShiftSpec("dynamics", "uniform", {"param": "dof_frictionloss", "index": "all",
                                                    "operation": "set", "nominal": 0.0,
                                                    "low": 0.0, "high": 1.0}),
    "push":       ShiftSpec("dynamics", "push", {"body": "torso", "interval": 250, "duration": 12,
                                                 "force": 60.0, "direction": "random_x"}),
    "transition": ShiftSpec("transition", "gauss", {"q_sigma": 0.001, "v_sigma": 0.01}),
}
Non-stationary, with the factor range written into the schedule:
NON_STATIONARY = ShiftSpec(
    "dynamics", "scale", {"param": "actuator_gear", "index": "all", "factor": 1.0},
    schedule={"type": "sine", "start": 0.8, "end": 1.2, "period": 200},
)
Composition, and the values it writes into the model:
env = make_robust("Hopper-v5", shifts=[
    ShiftSpec("dynamics", "scale", {"param": "gravity", "factor": 1.2}),
    ShiftSpec("dynamics", "scale", {"param": "actuator_gear", "index": "all", "factor": 0.8}),
], seed=0)
env.reset(seed=0)
model = env.unwrapped.model
print(round(model.opt.gravity[2], 3), model.actuator_gear[:, 0])
-11.772 [160. 160. 160.]
The names a task accepts are listed by its adapter.
from robustrllib.adapters import get_adapter

names = get_adapter(make_robust("Hopper-v5")).list_params()
Rules
- A parameter of one entity is always written with
index; withoutindexthe shift addresses entity 0, which for MuJoCo bodies is the world body. - A factor is relative to the nominal value, so repeated resets do not compound it.
- One parameter and index is addressed by one shift only; of two shifts on the same parameter the later one wins.
- A parameter whose nominal value is zero is randomized with
operation: setand anominal. translateis written for position vectors:body_pos_xyz,freejoint_pos,cam_posandlight_pos.- The drawn mode names are not combined with a schedule, because they would then draw at every step.
push,transitionandtranslateneed a MuJoCo task.